SO-101 Teleoperated Robot Arm
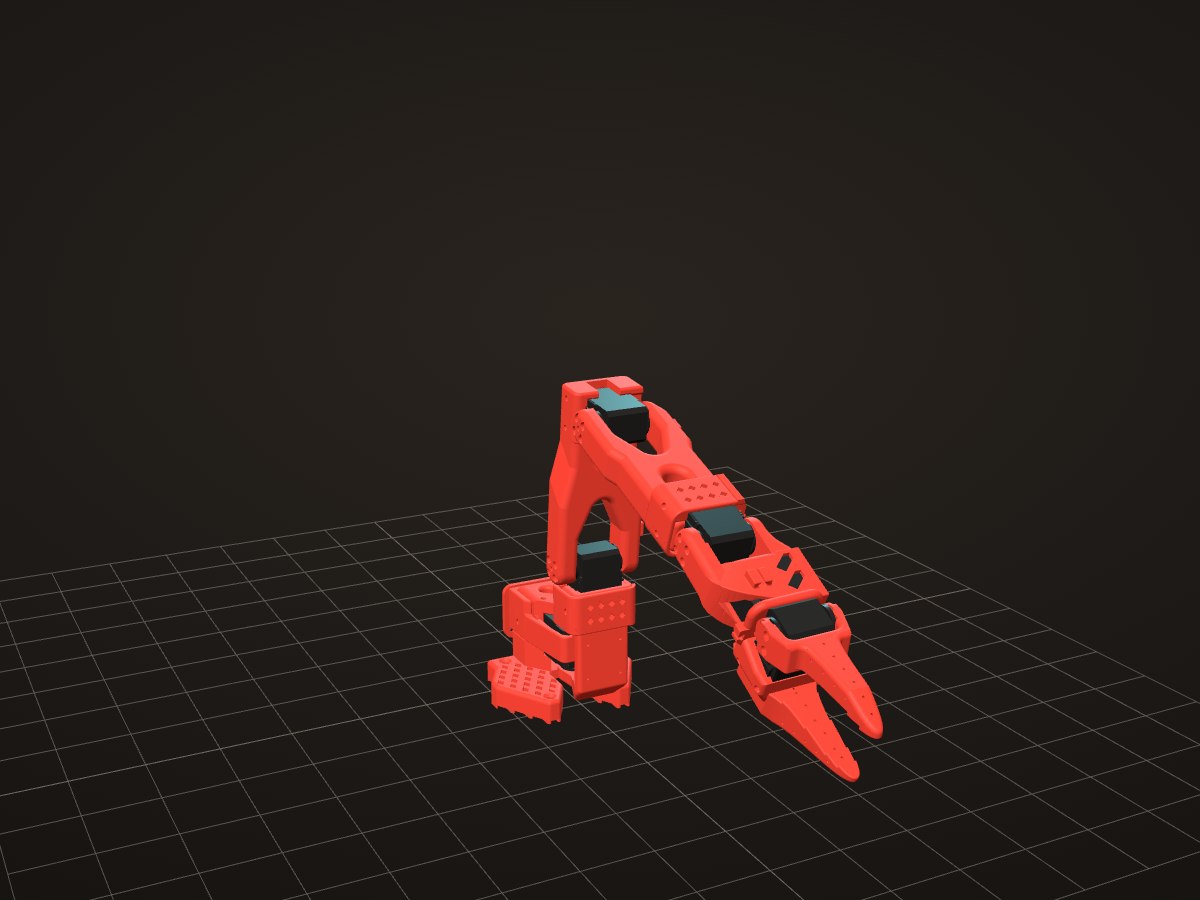
I assembled both arms of the open-source SO-101 as the team's mechanical engineer. The leader arm's trigger drives the gripper 1:1, and I measured its 111° stroke as the baseline for an ergonomic redesign.
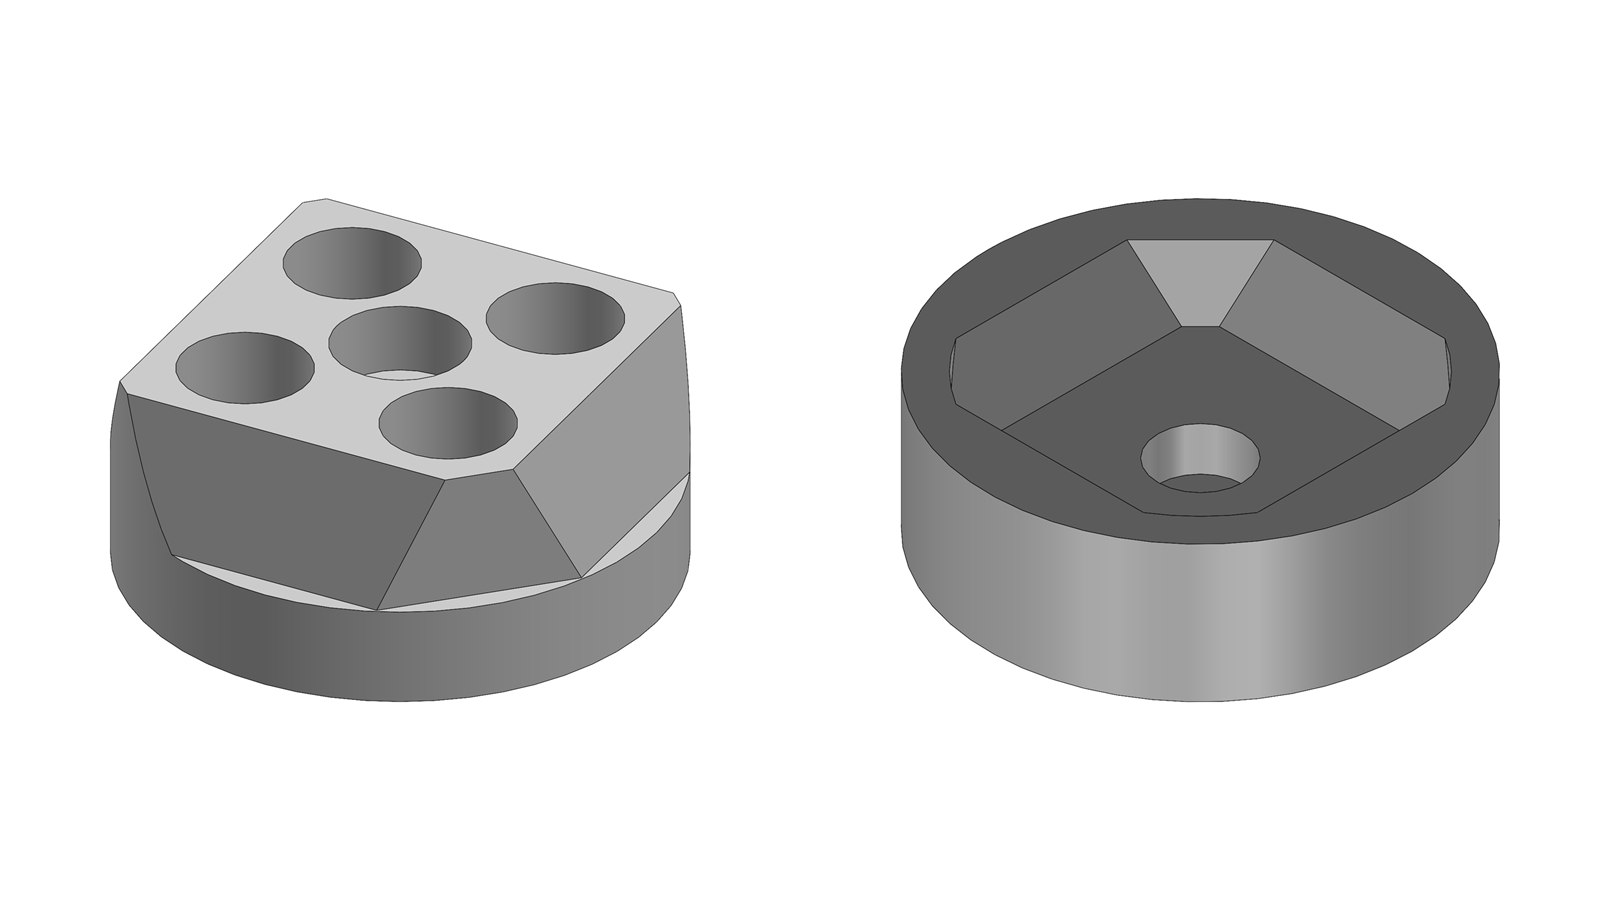
The stock handle strains the thumb, so I designed a tool-free magnetic interface in SolidWorks that makes the handle modular. Torque goes through a drafted square boss, and the first print seated as designed.
Read The Case Study →